Grip, Trace, Write: Force-Aware Imitation and Reinforcement Learning for High-DoF Robotic Handwriting

TL;DR
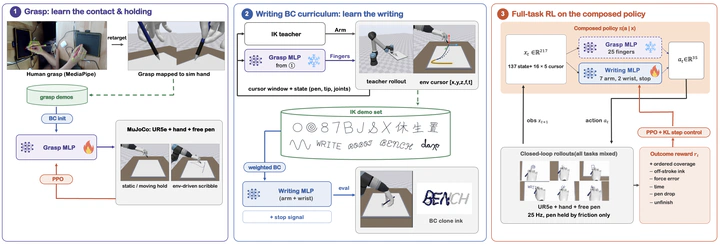
Grip, Trace, Write teaches a 25-DoF dexterous hand to write with a freely held pen, held by friction alone, while tracking both the stroke position and the requested contact force.
Key contributions:
- A staged learning framework: learn a reusable grasp controller, train a trajectory-conditioned writer from inverse-kinematics demonstrations, then improve it with RL on task-outcome rewards.
- A two-branch actor that separates hand stabilization from arm–wrist motion while keeping both closed-loop through the shared state and pen dynamics.
- Improves completion, precision, force regulation, and efficiency over behavior cloning and IK, and generalizes without fine-tuning to unseen English and Chinese content.
BibTeX
@inproceedings{chen2026griptracewrite,
  title={Grip, Trace, Write: Force-Aware Imitation and Reinforcement Learning for High-DoF Robotic Handwriting},
  author={Chen, Rongqian and Chen, Yiding and Zhou, Jijie and Jiahao, Tom Z.},
  booktitle={CoRL 2026 Workshop PhysicalWM},
  year={2026}
}